You're invited
Meet the Team
Our research team is at CoRL in Austin, sharing insights on Scaling Self-Play for End-to-End Driving. When the day's programming wraps, join us for drinks and appetizers with the engineers and research scientists building TorcDrive.
Space is limited, so let us know you're coming. All attendees must register for the event beforehand.
DateWednesday, November 11, 2026
Time6:00 - 8:00 PM CT
VenueAustin Taco ProjectInside Hilton Austin, 500 E 4th St, Austin, TX 78701 | Google Map
Who you'll meet in Austin


Scaling Self-Play for End-to-End Driving
End-to-end driving models trained on human demonstrations see a narrow slice of the world and compound their own errors once they are in the loop. We train from pixels in simulation instead, introducing Gigapixel, a batched driving simulator running 50,000 agent steps per second, then transfer those self-play policies to real sensor data through lightweight perception adaptation. Scaling the self-play scales the performance.

Dataset
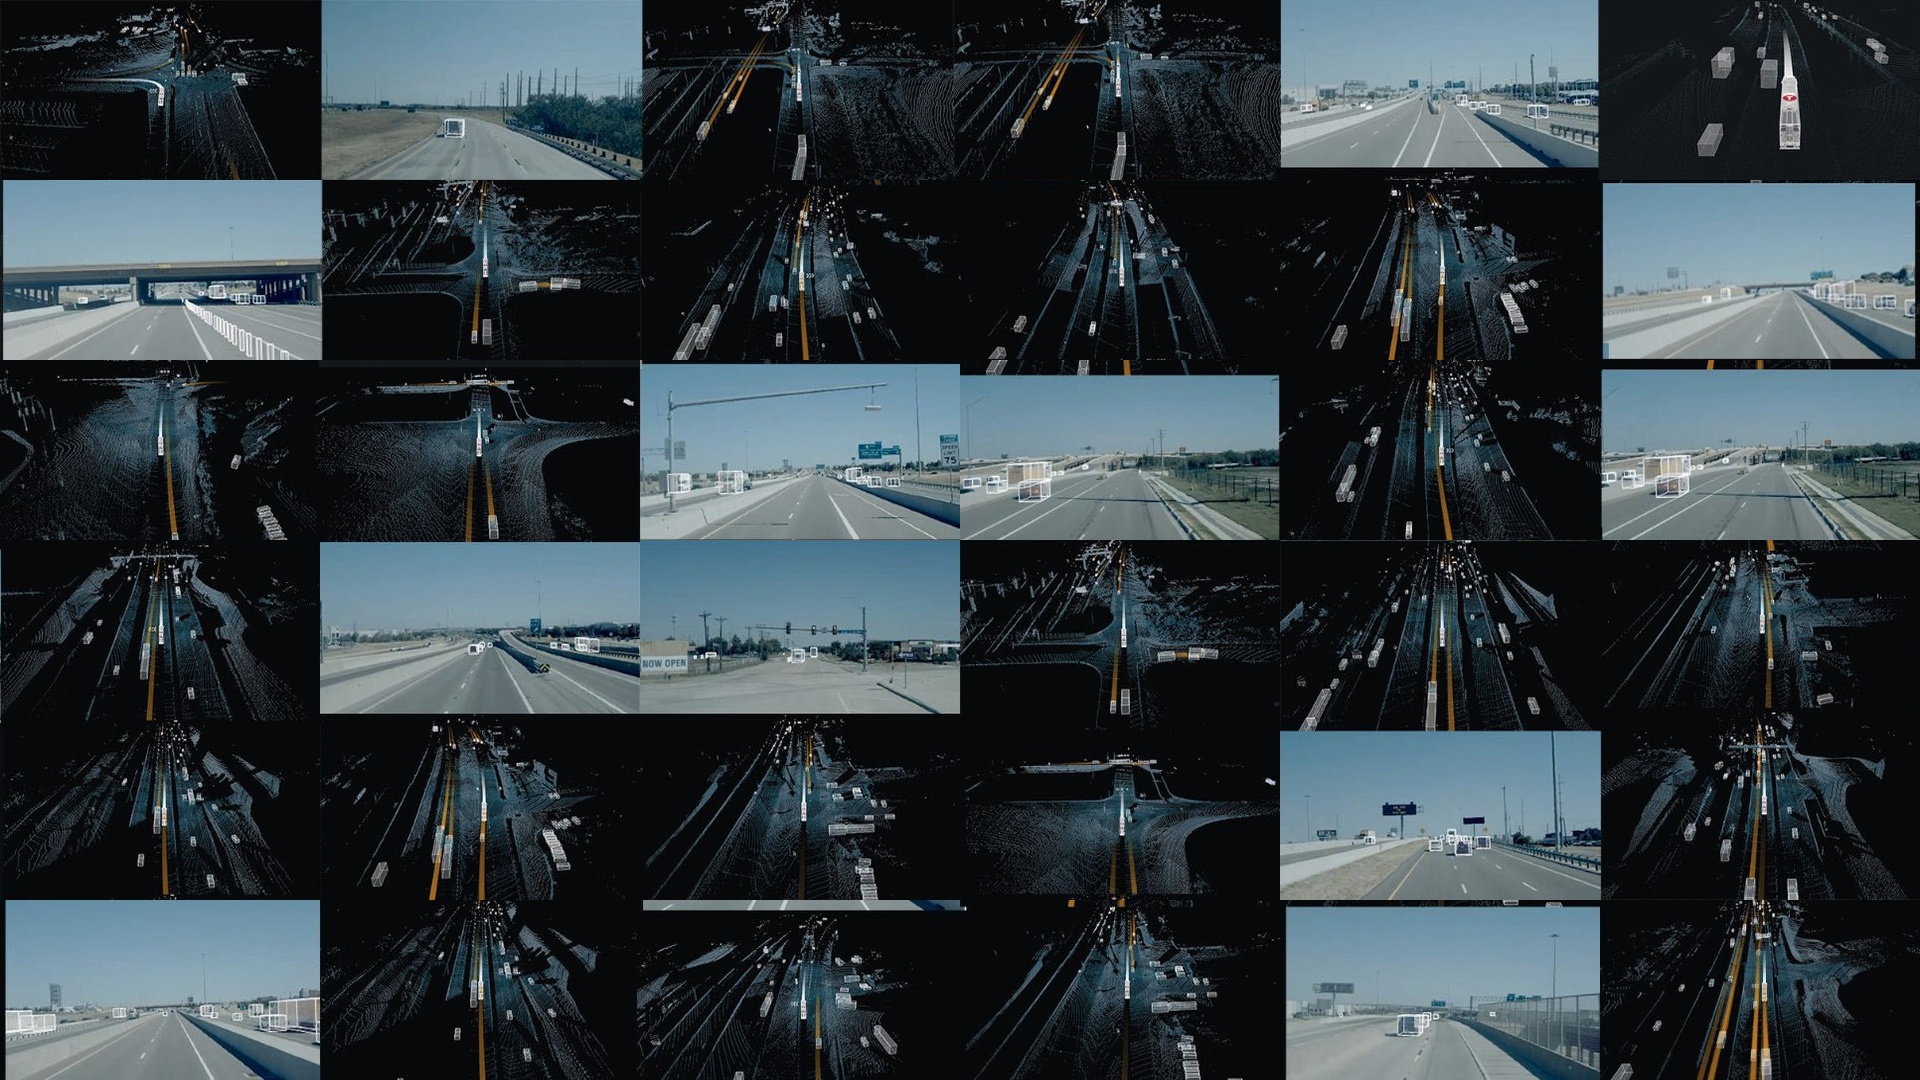
TruckDrive: Long-Range Autonomous Highway Driving Dataset
475,000 samples built on a sensor suite designed for long-range highway perception, with benchmarks out to 1,000 meters.
Perception
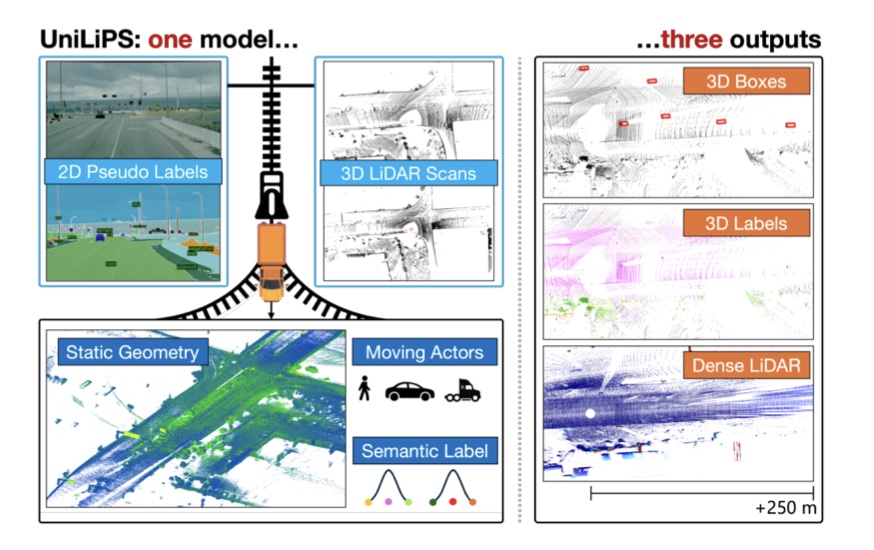
UniLiPs: Unified LiDAR Pseudo-Labeling
Jointly produces 3D semantic labels, bounding boxes and densified scans, improving depth prediction MAE by 51.5% at 80–150 meters.

Reconstruction
Transient LASSO: Transient Large-Scale Scene Reconstruction
Neural scene reconstruction from raw transient measurements of outdoor in-the-wild captures.
Sensor fusion
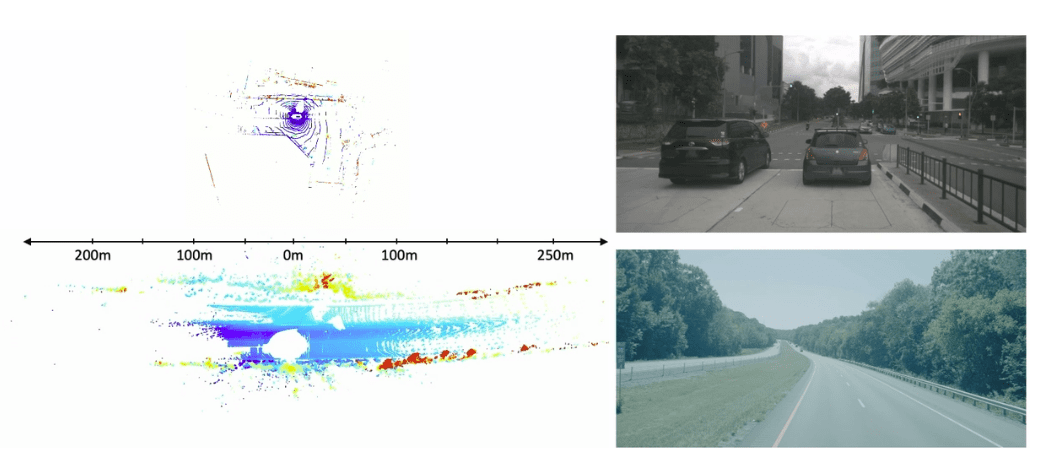
Self-Supervised Sparse Sensor Fusion for Long Range Perception
Fusing camera and lidar to extend perception to 250 meters, with a 26.6% improvement in detection mAP.
Workforce
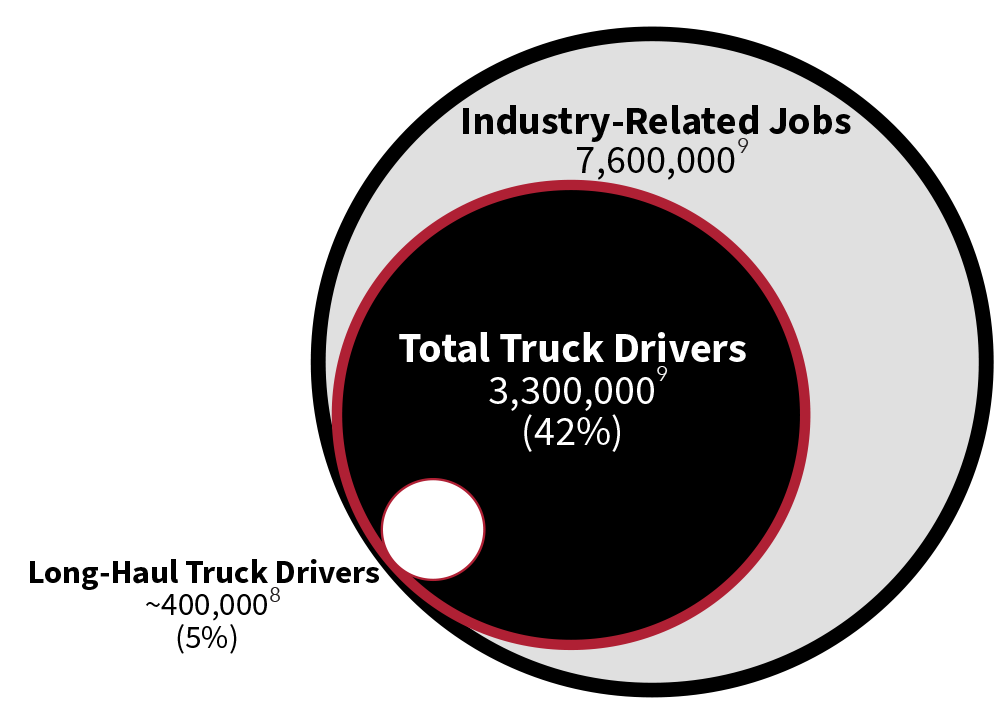
Potential Workforce Impacts of Autonomous Trucks
What automation actually changes for the trucking workforce: augmenting the job rather than replacing it.

Safety
Introducing the ML FMEA
A structured approach to safe machine-learning development for safety-critical sectors.
Careers at Torc
Physical AI at highway scale starts with the people building it
- Machine Learning Engineer II - Learned Planning (Reinforcement Learning)
- Staff, ML Engineer - Scene Generation
- Staff, Software Engineer - Simulation Vehicle Modeling
- Senior, ML Engineer - VLM
- Staff, Machine Learning Engineer - BEV/Multi-Modal Perception
- Senior, Machine Learning Engineer - 3D Perception
- Machine Learning Engineer, II - 3D Perception
- Senior, Machine Learning Engineer - Camera Model
- Senior, ML Engineer - Tracking
- Engineering Manager, Active Sensors (LiDAR)
- Senior Machine Learning Engineer - Localization